
How Real-Time Iteration NMPC Solves Offshore Wind Turbine Control in Under 5 Milliseconds
We compile, generate and translate using Artificial Intelligence from the below given source. Macro Micro News is responsible for its editorial publication.
Global, Source:
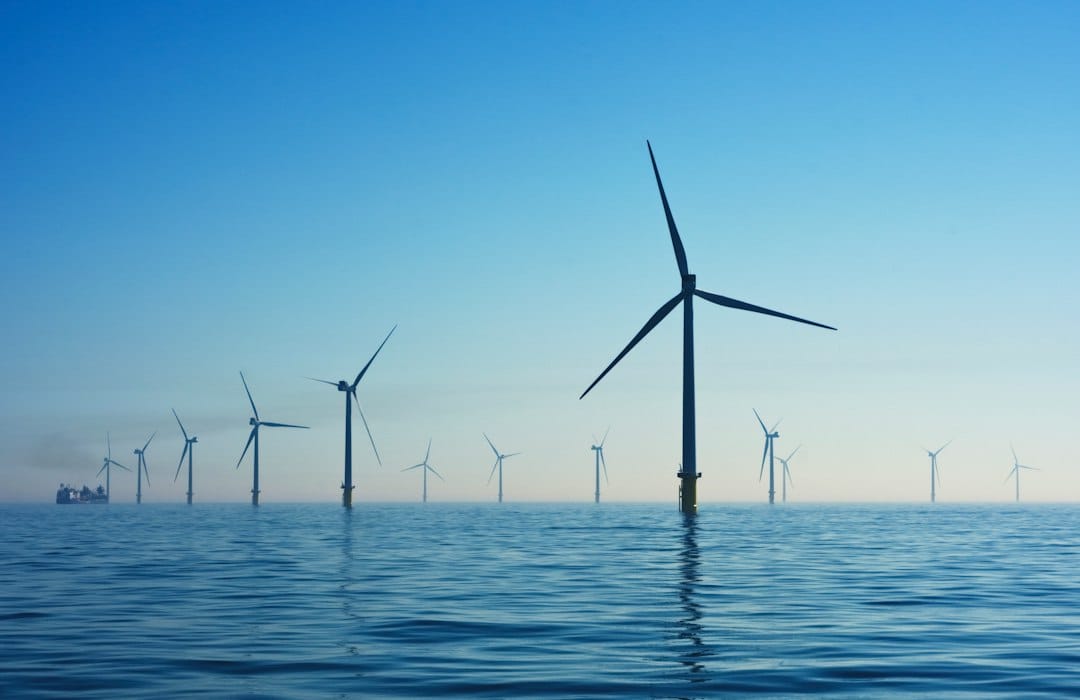
Offshore wind turbines equipped with full-power converters face a complex control challenge that requires the simultaneous coordination of power tracking, electrical safety, and mechanical load mitigation. While Nonlinear Model Predictive Control offers a systematic framework for addressing this multi-objective problem, standard implementations often fail to meet the stringent computational demands of commercial turbines. Traditional methods solve the nonlinear program to full convergence at every control step, resulting in computation times that are incompatible with the 10 to 100 millisecond control periods required for stable operation.
Existing formulations frequently omit critical electrical hard constraints and rely on expensive lidar systems for wind speed feedforward, limiting their practical deployment. To overcome these limitations, a novel Real-Time Iteration NMPC framework has been proposed. This approach performs a truncated real-time iteration at each control step, executing a single inexact Sequential Quadratic Programming step realized by at most five interior-point Newton iterations on the parametric Nonlinear Program.
The system utilizes warm-start initialization and a solution-shift strategy to enhance efficiency. Crucially, torque command amplitude bounds and a DC-link voltage deadband are embedded as hard bounds on the predicted trajectory within the Optimal Control Problem. Additionally, the torque rate limit is enforced through a dual mechanism involving a quadratic penalty in the cost function and a plus or minus 15 kN·m/s hard saturation at the solver output.
The controller employs a second-order autoregressive predictor to supply wind speed feedforward over a two-second horizon, with the power-tracking weight adaptively adjusted based on prediction confidence. Ablation experiments highlight the importance of the warm-start solution-shift mechanism; removing it degrades power-tracking Root-Mean-Square Error by up to 370% under grid load-drop transients.
Comparative simulations across four operating scenarios demonstrate that the proposed controller achieves an average per-step computation time of 3.796 to 4.313 ms, approximately one order of magnitude faster than standard NMPC. Under grid load-drop scenarios, the root-mean-square power-tracking error is reduced by 78.1% and 78.5% relative to a PI controller and standard NMPC, respectively.
These results confirm the computational feasibility and engineering potential of electrically constrained, lidar-free RTI-NMPC for coordinated power-tracking and electrical constraint management in offshore FPC wind turbines. The ability to execute such sophisticated control logic within such tight timeframes opens new avenues for reliable renewable energy integration without the need for costly external sensing hardware.
Related in Gadgets

Gadgets
How SMHA Solves the AI Image Quality Puzzle: A New Framework for Precision
The surge in text-to-image generation has reshaped digital creation, yet it brings a pressing question: how do we truly measure the quality of these synthetic visuals? Traditional photos face physical issues like blur or noise, but AI-generated images present a more complex land…
Read More...
Gadgets
How AI Stops Cyberattacks in P2P Energy Markets: Real-Time Detection Explained
The smart grid is undergoing a profound transformation. We are moving away from centralized power plants toward decentralized networks where energy flows bidirectionally. This shift relies on integrating information technology with physical infrastructure. Modern grids now facil…
Read More...
Gadgets
How to Cool EV Motors: The 31% Efficiency Gain in PMSM Design
The push for electric vehicles is accelerating at a rapid pace. This shift brings a significant engineering hurdle to the forefront. Thermal management in permanent magnet synchronous motors has become a critical challenge. Modern drivetrains generate intense heat. This heat con…
Read More...
Gadgets
How AI-Driven RIS on High-Altitude Platforms Boosts Energy Efficiency for IoT
Global, Source In remote rural areas and disaster zones Internet of Things devices often face a frustrating reality weak or blocked connections to terrestrial base stations. This connectivity gap creates significant hurdles for critical applications such as environmental monitor…
Read More...
Gadgets
How the Nautical δ-Corridor Ensures Safe Autonomous Ship Navigation
The maritime industry stands at a pivotal moment as autonomous surface ships move from experimental phases to regulated commercial deployment. A critical challenge remains: ensuring navigational safety while strictly adhering to international collision regulations. Researchers h…
Read More...
Gadgets
How L1* Regularization Transforms Multi-Modal Anomaly Detection: A New Standard for Semantic Accuracy
In a world where data streams from countless sources, traditional anomaly detection often struggles to keep pace. Most existing algorithms rely on single-modal inputs like text or images alone, missing the intricate correlations that define real-world scenarios. This limitation…
Read More...
Gadgets
How Deep Learning Keeps Remote Solar Security Systems Online
Maintaining uninterrupted surveillance in remote locations presents a unique engineering challenge. Unlike urban infrastructure powered by stable electrical grids, solar-powered security systems rely entirely on intermittent renewable energy sources and finite battery storage. A…
Read More...
Gadgets
How Failure-Guided Control Boosts Au-Wire Bonding Strength by 3x on Silicon Submounts
As programmable photonic integrated circuits expand to support higher port counts and system-level reconfigurability, high-density electrical fan-out has become a critical packaging bottleneck. In the realm of silicon photonics, particularly for devices like optical field-progra…
Read More...
Gadgets
FSA-Net: How Deep Learning Pinpoints Unknown Signal Sources with Sub-Degree Precision
Imagine trying to locate multiple whispers in a noisy room without knowing how many people are speaking or where they stand. This is the daily reality for engineers working with wireless communications and radar systems. Traditional tools like MUSIC and ESPRIT have long been the…
Read More...
Gadgets
DyMC-YOLO: How Dual-Stream Fusion Boosts Real-Time Detection to 46 FPS
Object detection stands as a fundamental pillar of intelligent visual perception. It powers critical advancements in autonomous driving, security surveillance, and precision agriculture. Yet traditional visible-spectrum detectors often falter under adverse conditions like low il…
Read More...